> ## Documentation Index
> Fetch the complete documentation index at: https://docs.creaturetec.com/llms.txt
> Use this file to discover all available pages before exploring further.

# Specifications

> Prime Hand structure, performance, electrical interfaces, joint ranges, tactile sensing, and environmental specifications.

## General

| Parameter | VALUE |
| - | - |
| Degrees of Freedom | 22 DOF (actively actuated)<br />4 DOF per digit × 5 digits + 2 wrist DOF |
| Palm Dimensions | Palm: 18.5 × 8 × 4.5 cm |
| Forearm Dimensions | Complete hand assembly: 43 × 8.5 × 8.2 cm |
| Weight | Palm: approx. 300 g; complete hand assembly: approx. 2 kg |

## Performance

| Parameter | VALUE |
| - | - |
| Maximum Fingertip Force | 50N |
| Maximum Grasping Payload | ＞40KG |
| Fingertip Positioning Repeatability | 0.05mm |
| Joint Positioning Repeatability | 0.1° |
| Maximum Opening/Closing Speed | 1.5 s/cycle |
| Backdrive Torque | ＜0.05N |

## Electrical & Communication

<div className="overflow-x-auto">
  <table className="w-full">
    <thead>
      <tr>
        <th scope="col">Category</th>
        <th scope="col">Parameter</th>
        <th scope="col">VALUE</th>
      </tr>
    </thead>

    <tbody>
      <tr>
        <td rowSpan={3} style={{ verticalAlign: "top" }}>Electrical Specifications</td>
        <td style={{ paddingLeft: "8px" }}>Operating Voltage</td>
        <td>36–60 V (nominal: 48 V)</td>
      </tr>

      <tr>
        <td style={{ paddingLeft: "8px" }}>No-load Current</td>
        <td>0.5A</td>
      </tr>

      <tr>
        <td style={{ paddingLeft: "8px" }}>Standby Current</td>
        <td>0.3A</td>
      </tr>

      <tr>
        <td rowSpan={3} style={{ verticalAlign: "top" }}>Control and Communication</td>
        <td style={{ paddingLeft: "8px" }}>Control Frequency</td>
        <td>200Hz</td>
      </tr>

      <tr>
        <td style={{ paddingLeft: "8px" }}>Control Mode</td>
        <td>Joint-level MIT Control Mode</td>
      </tr>

      <tr>
        <td style={{ paddingLeft: "8px" }}>Communication Interface</td>
        <td>RJ45 Ethernet</td>
      </tr>
    </tbody>
  </table>
</div>

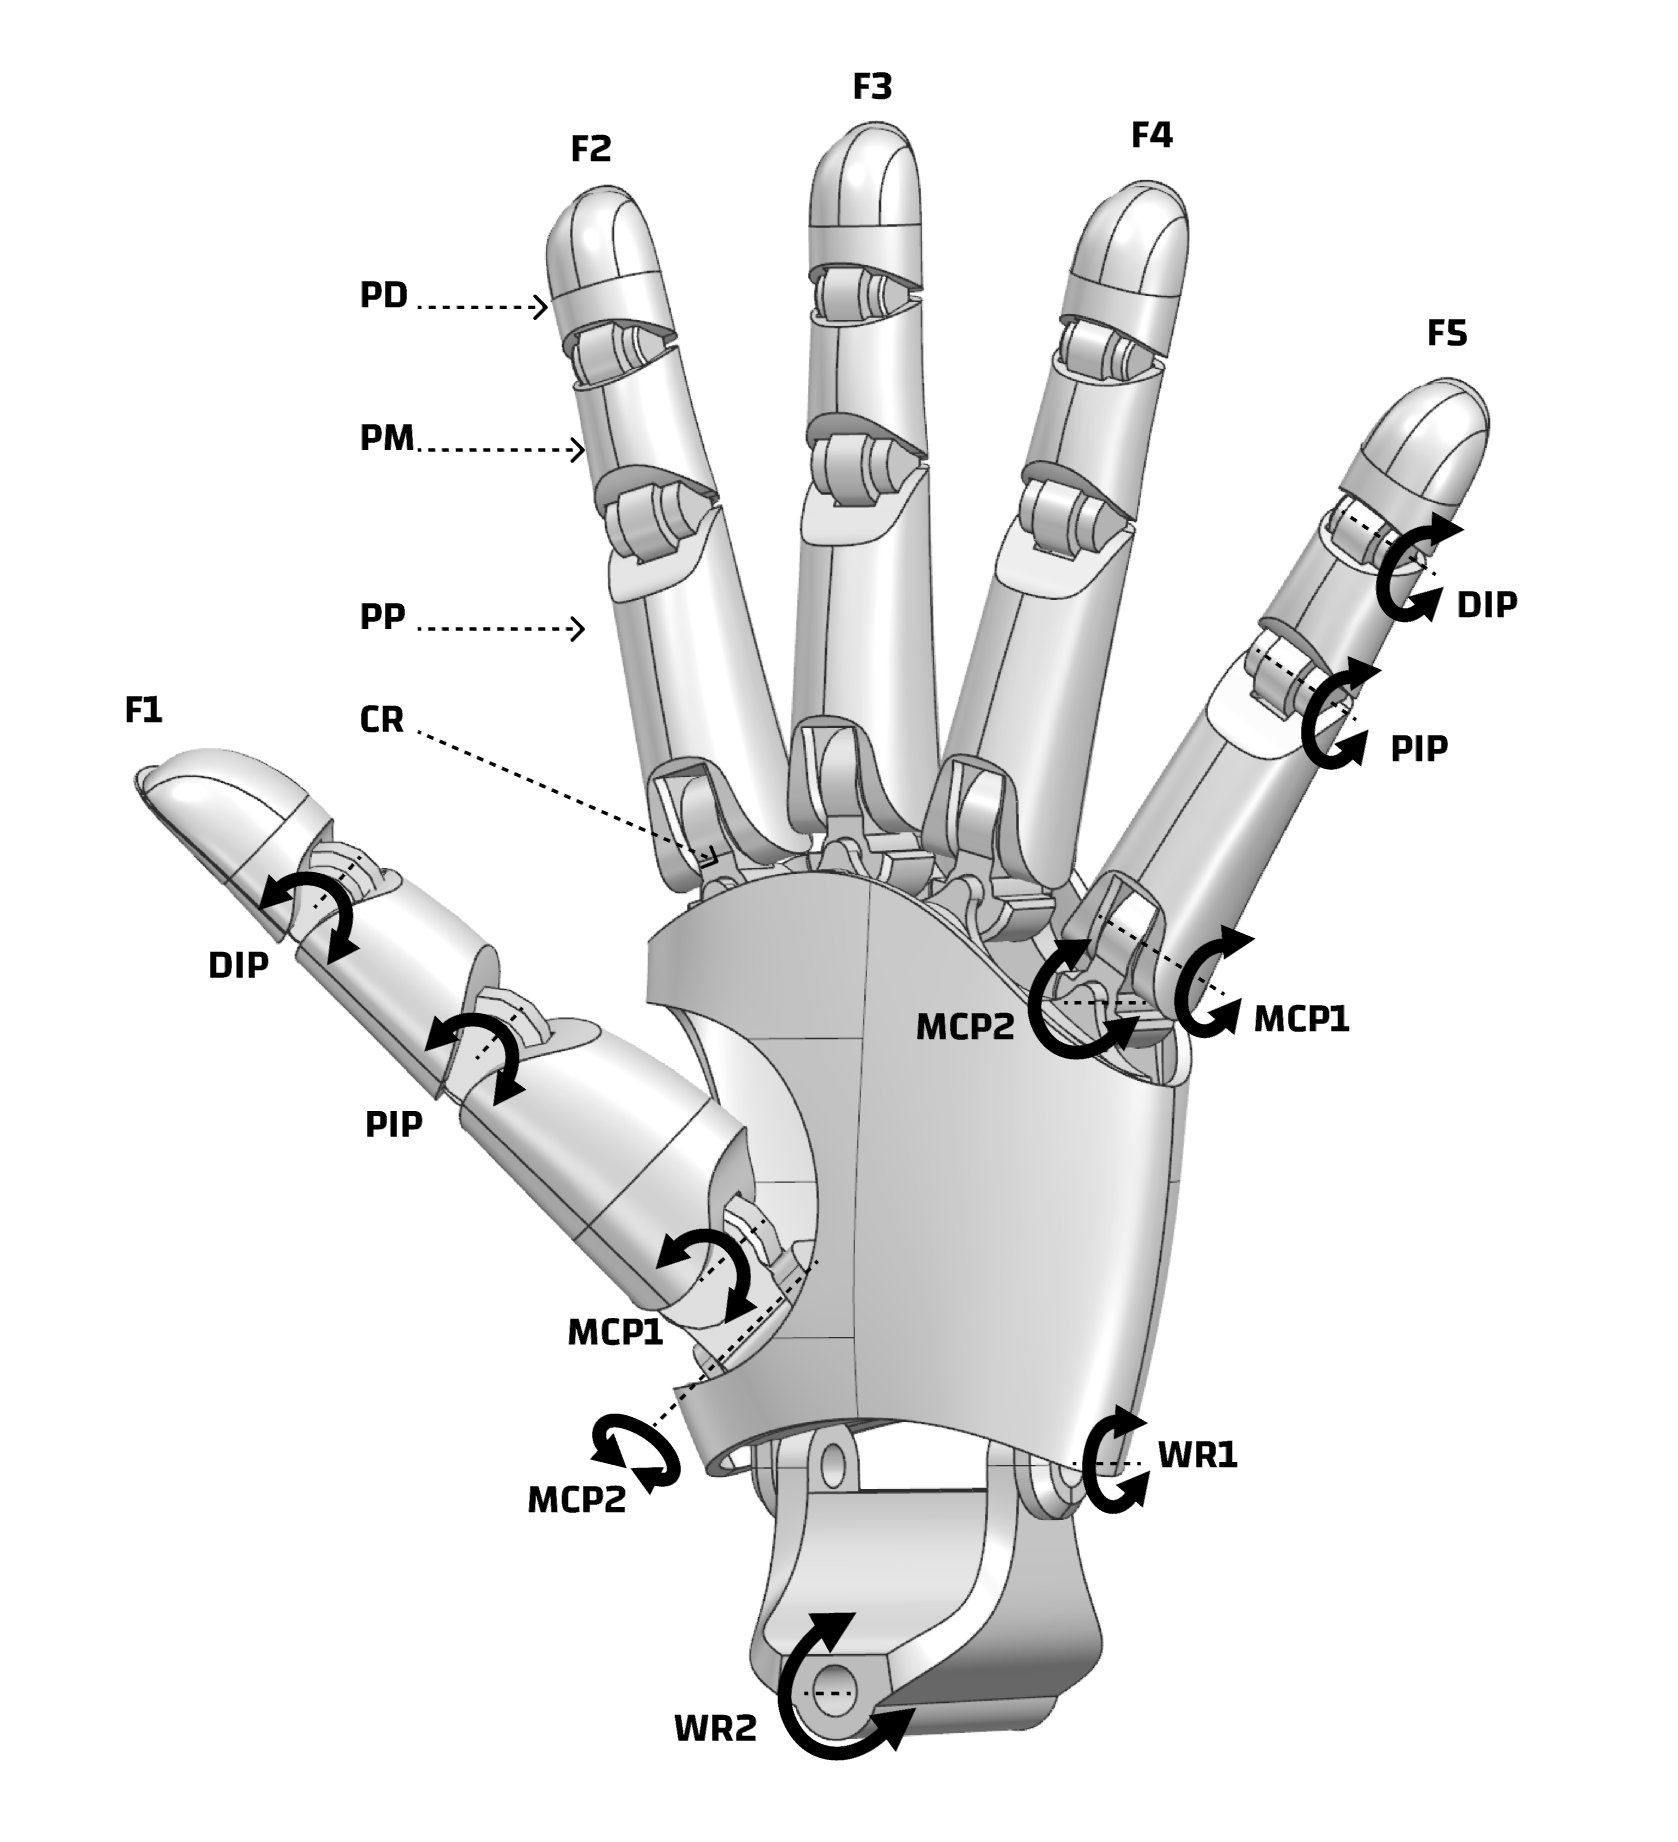
## Range of Motion

1. **Flexion–Extension**
   * Positive angle: toward the palm (flexion).
   * Negative angle: toward the back of the hand (extension).
2. **Abduction–Adduction**
   * **Fingers:** positive angle toward the thumb side; negative angle toward the little-finger side.
   * **Thumb:** positive angle toward the palm (flexion); negative angle toward the back of the hand (extension).
3. **Wrist Motion**
   * **WR1:** positive angle toward the palm (wrist flexion); negative angle toward the back of the hand (wrist extension).
   * **WR2:** positive angle toward the thumb side; negative angle toward the little-finger side.

<img src="https://mintcdn.com/creature/caCm-qww038_uGNe/images/prime-hand-range-of-motion-r1719.png?fit=max&auto=format&n=caCm-qww038_uGNe&q=85&s=459e585aa47a3dbebc3913057a749c9f" alt="Prime Hand joint motion directions" width="1678" height="1842" data-path="images/prime-hand-range-of-motion-r1719.png" />

**Degrees of freedom: 22 actuated DOF (including the wrist)**

| | **Fingers** | **Thumb** | **Wrist** |
| - | - | - | - |
| **DIP — Flexion/Extension** | -5° to +75° | -25° to +80° | |
| **PIP — Flexion/Extension** | -5 to +105° | -30° to +75° | |
| **MCP1 — Flexion/Extension** | -35° to +95° | -35° to +50° | |
| **MCP2 — Abduction/Adduction** | F2: -30° to +40°<br />F3: -40° to +35°<br />F4:-40° to +30°<br />F5:-40° to +30° | -25° to +45° | |
| **WR1** | | | -70° to 70° |
| **WR2** | | | -45° to 45° |

## Tactile Sensors

| Parameter | VALUE |
| - | - |
| Data Update Rate | 100Hz |
| Activation Force | 0.2N |
| Measurement Range | 20N/cm² |
| Overload Protection | 40N/cm² |
| Force Resolution | 0.05N |
| Accuracy | 10% F.S. |
| Repeatability | 5% F.S. |
| Localization Accuracy | 0.5mm |
| Minimum Resolution | 0.5mm |
| Spatial Resolution | 8\*16\*0.5mm<br />8\*4\*0.5mm<br />8\*12\*0.5mm |
| Compression Cycle Life | 1,000,000 cycles |
| Abrasion Cycle Life | 1,000,000 cycles |

## Environmental & Reliability

| Parameter | VALUE |
| - | - |
| Operating Temperature | 0°C to 60°C |
| IP Rating | IP20 |
| Humidity | \< 60% RH |
| Nominal Lifetime | >200,000 cycles (no load) |
| Tactile Sensor Lifetime | >1,000,000 cycles @20N |

***

Source: [Specifications](https://ncn5zs910x3g.feishu.cn/wiki/L000wEZ0WiXGOQkB9HfcTJM7nhc). Synced source revision: 1700.


This documentation is built and hosted on [Mintlify](https://mintlify.com), a developer documentation platform.