
General
Performance
Electrical & Communication
| Category | Parameter | VALUE |
|---|---|---|
| Electrical Specifications | Operating Voltage | 36–60 V (nominal: 48 V) |
| No-load Current | 0.5A | |
| Standby Current | 0.3A | |
| Control and Communication | Control Frequency | 200Hz |
| Control Mode | Joint-level MIT Control Mode | |
| Communication Interface | RJ45 Ethernet |
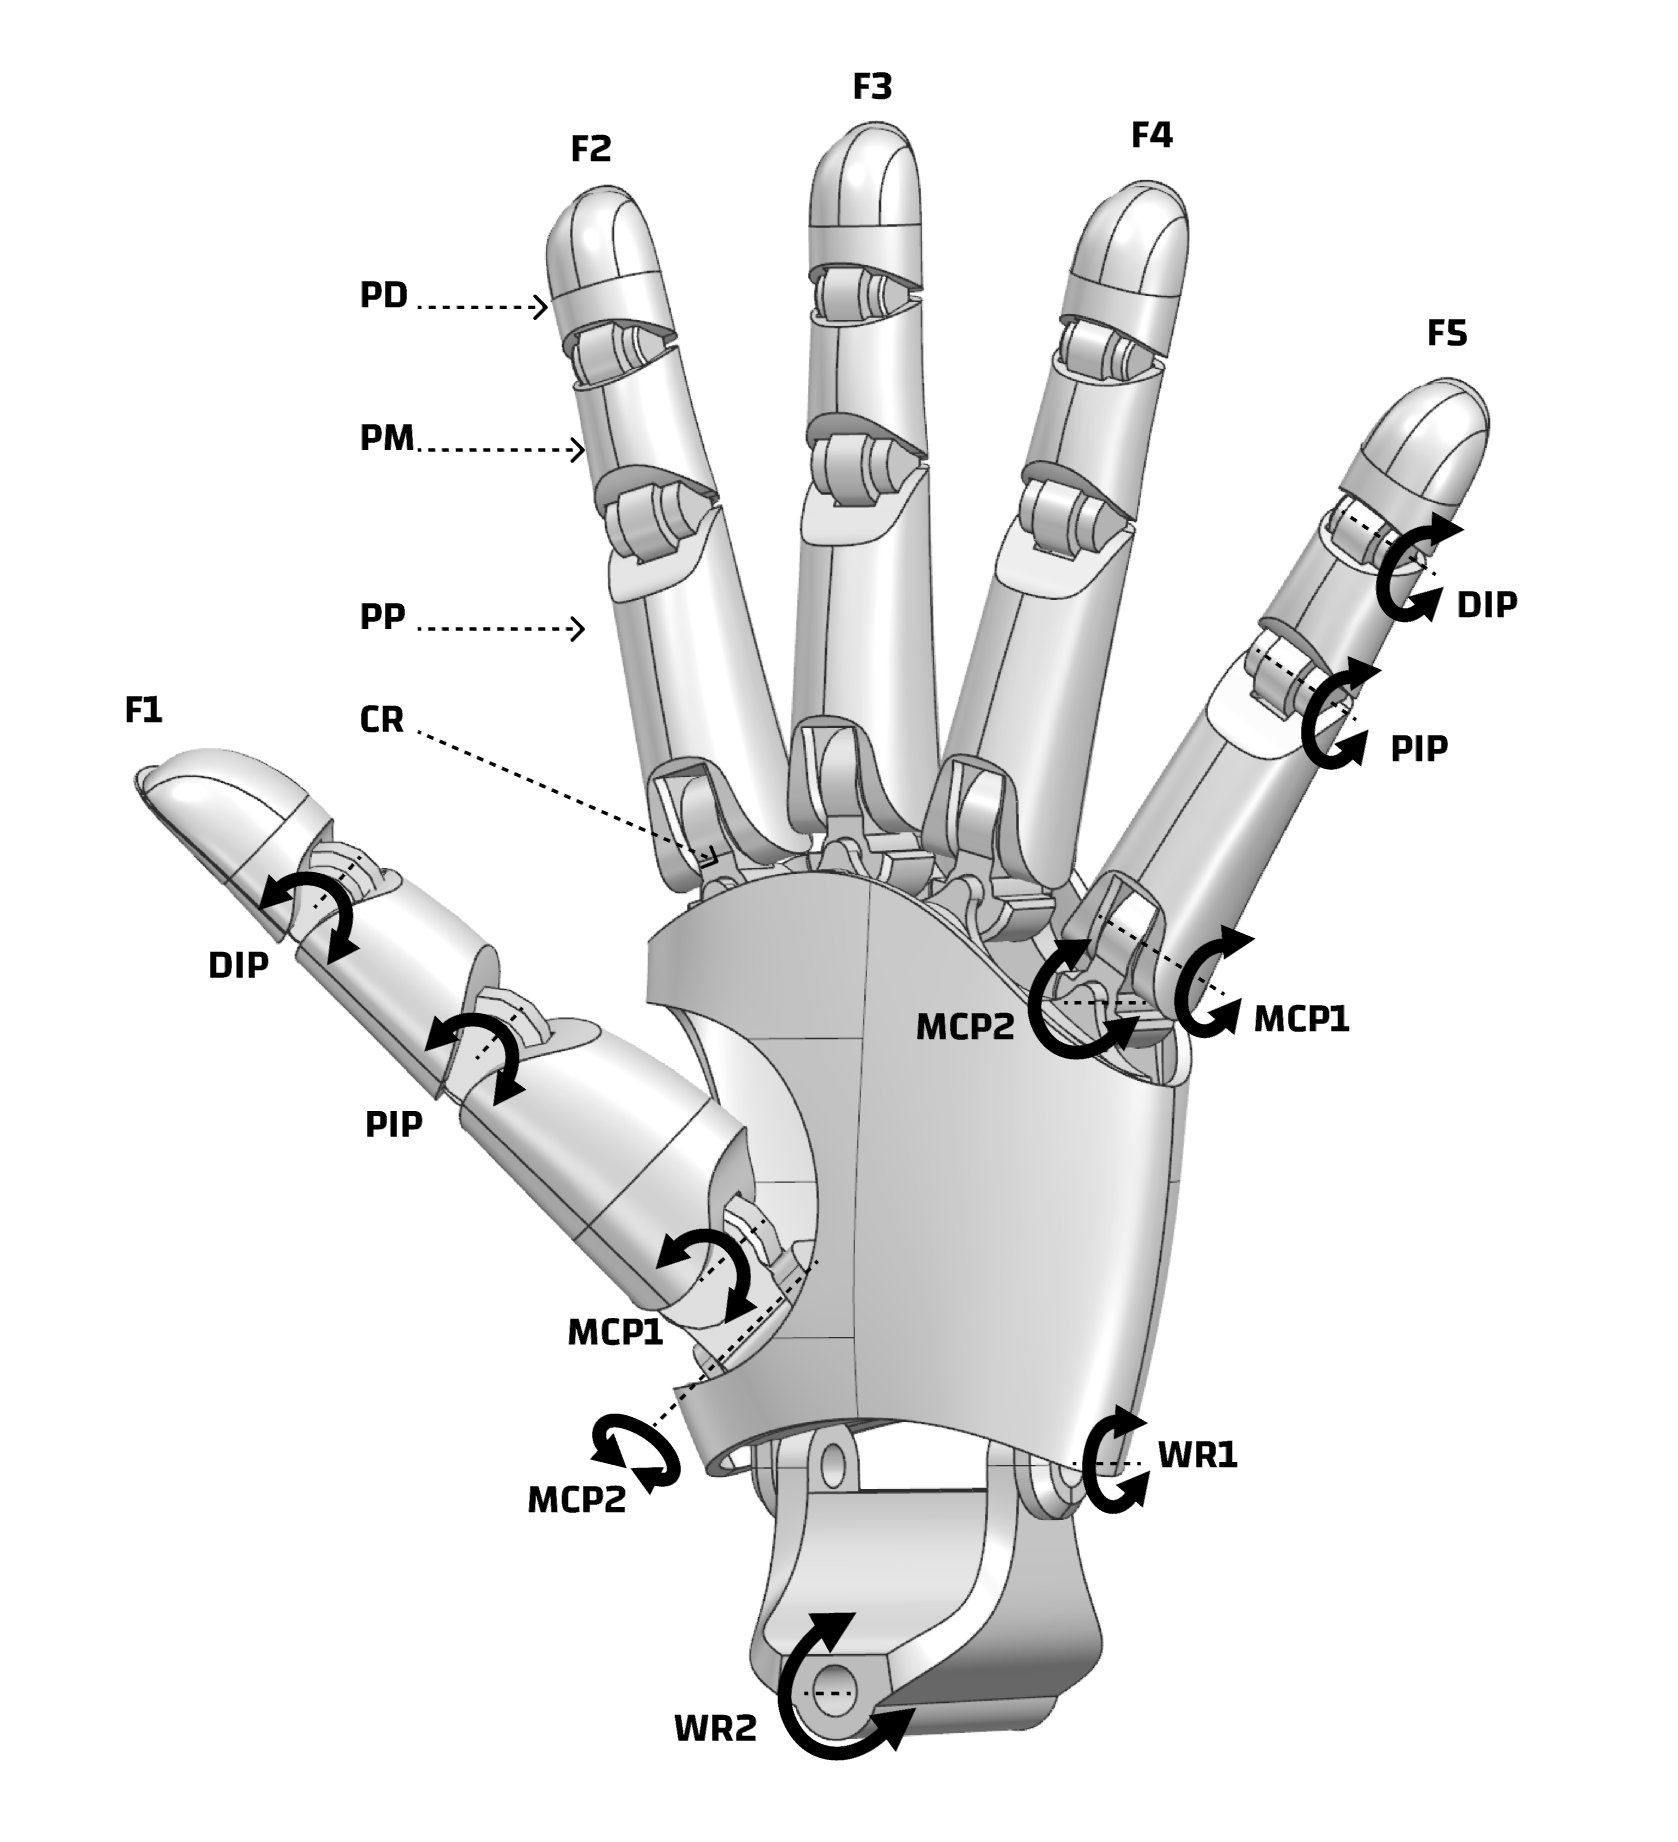
Range of Motion
- Flexion–Extension
- Positive angle: toward the palm (flexion).
- Negative angle: toward the back of the hand (extension).
- Abduction–Adduction
- Fingers: positive angle toward the thumb side; negative angle toward the little-finger side.
- Thumb: positive angle toward the palm (flexion); negative angle toward the back of the hand (extension).
- Wrist Motion
- WR1: positive angle toward the palm (wrist flexion); negative angle toward the back of the hand (wrist extension).
- WR2: positive angle toward the thumb side; negative angle toward the little-finger side.
Tactile Sensors
Environmental & Reliability
Source: Specifications. Synced source revision: 1700.